Autonomous Soccer Robot: Electronics Division Leadership & PCB Design
Project Overview
As the Electronics Division Lead for the Gadjah Mada Robotic Team (Fukuro), I led the development of electronic systems for autonomous soccer robots competing in KRSBI (Indonesian Soccer Robot Competition). My role included hardware architecture design, division management, and the development of key power management and actuation circuits.
Core Contributions & Technical Execution
1. Electronics Division Leadership
- The Challenge: Managing the development of a full-scale electronic architecture for a high-performance autonomous robot.
- My Execution: I supervised the design and production of the robot’s entire PCB suite, leading the team through the development of:
- Power Supply Unit (PSU) Board
- STM32 Shield & Motor Driver Hubs
- System Integration & Cabling Architecture
- Component Selection & Signal Integrity Management
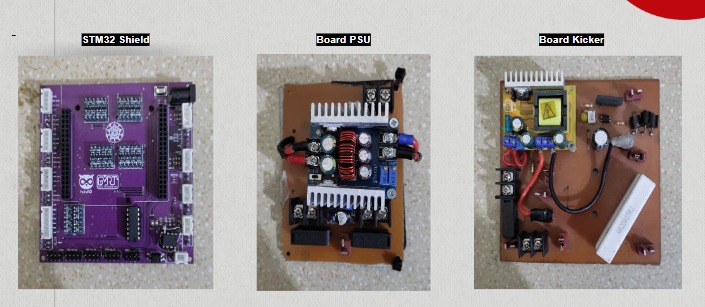
Figure 1. STM32 shield, PSU board, and solenoid kicker board.
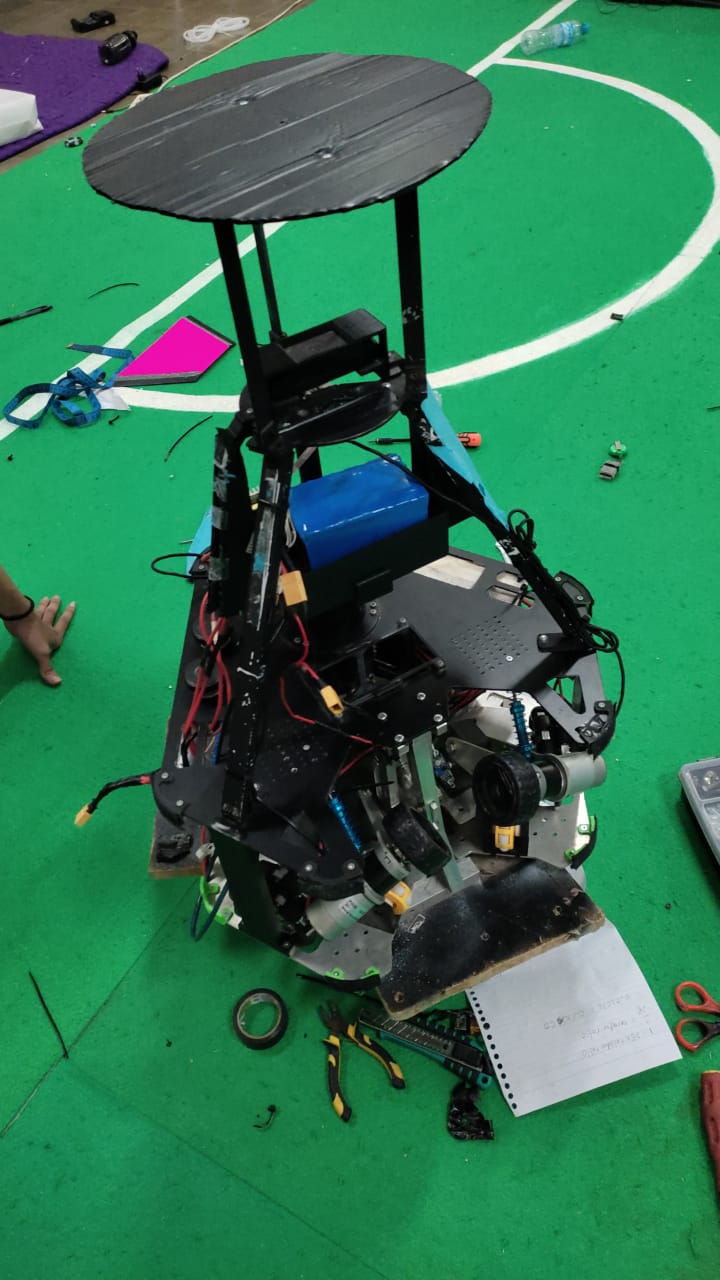
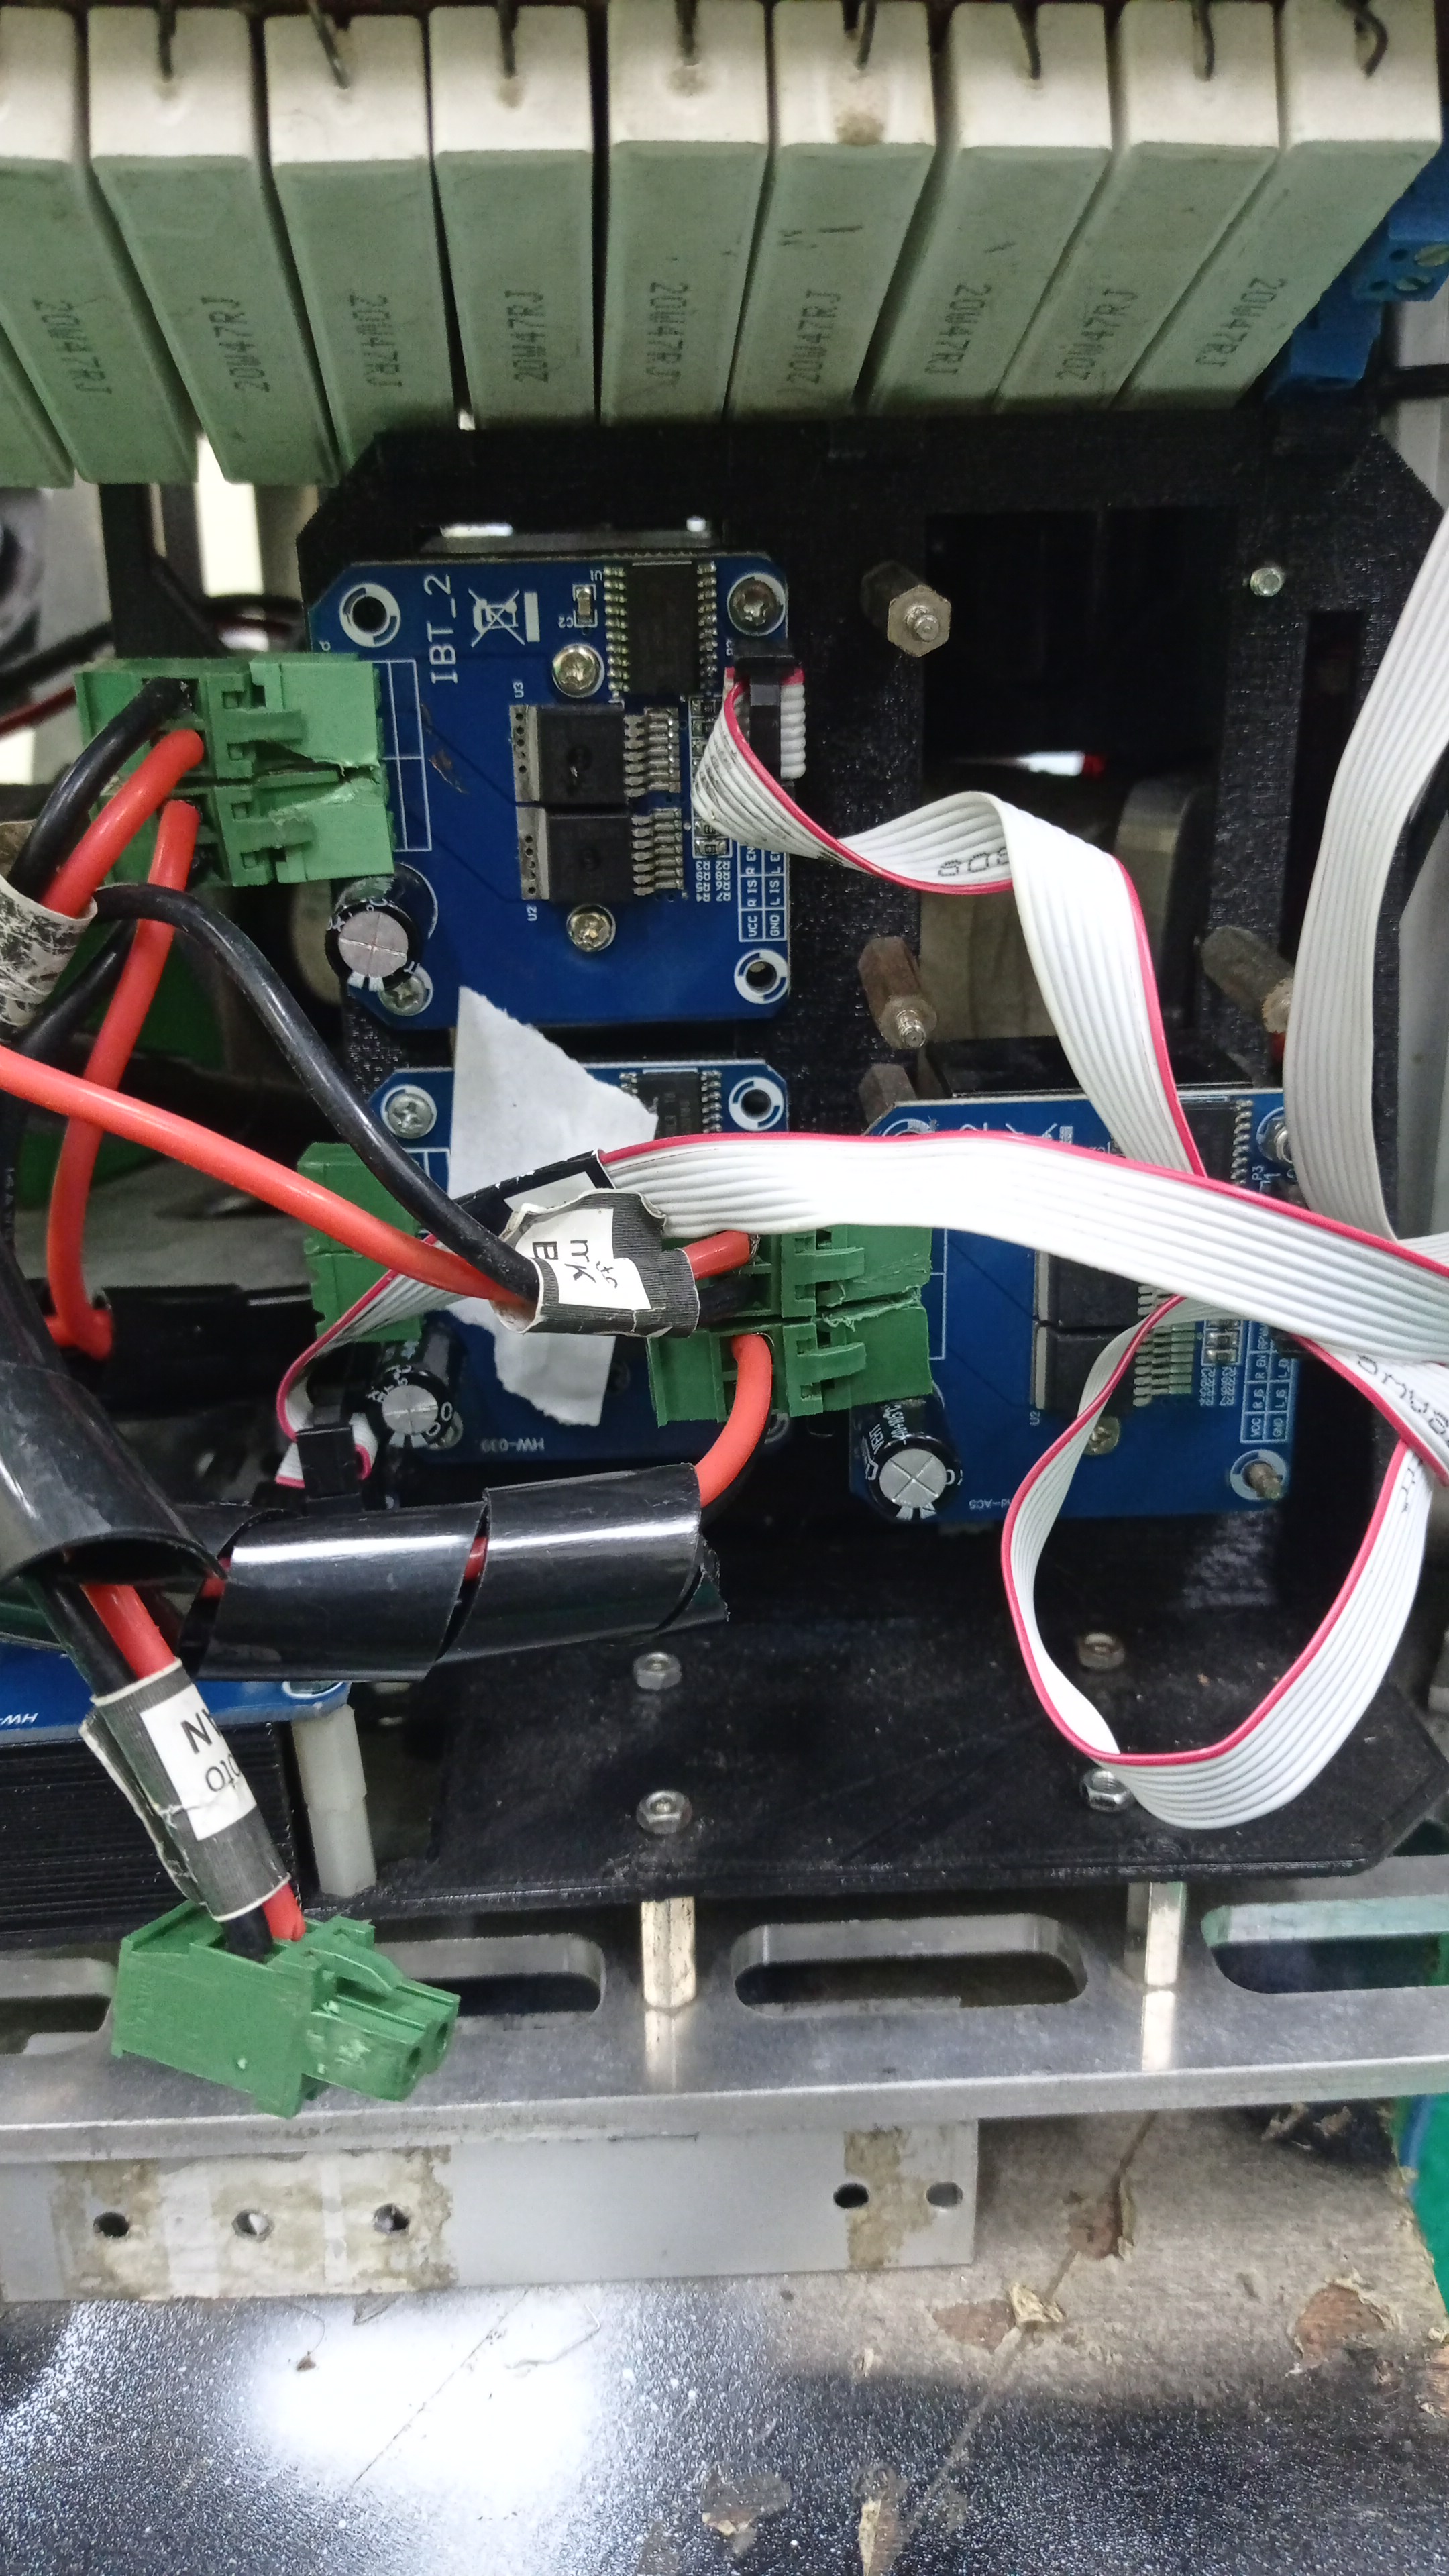
Figure 2. The autonomous robot system.
2. High-Voltage Solenoid PCB
- The Challenge: Designing a power electronic system to drive a solenoid kicker with high force and millisecond precision while ensuring safe control of high-voltage capacitor discharge.
- My Execution: I designed the Solenoid Kicker PCB for autonomous robot. I developed a high-power switching stage to discharge high-voltage capacitors into the solenoid actuator. I also optimized the PCB layout to handle high-current transients and applied signal isolation to improve hardware reliability.
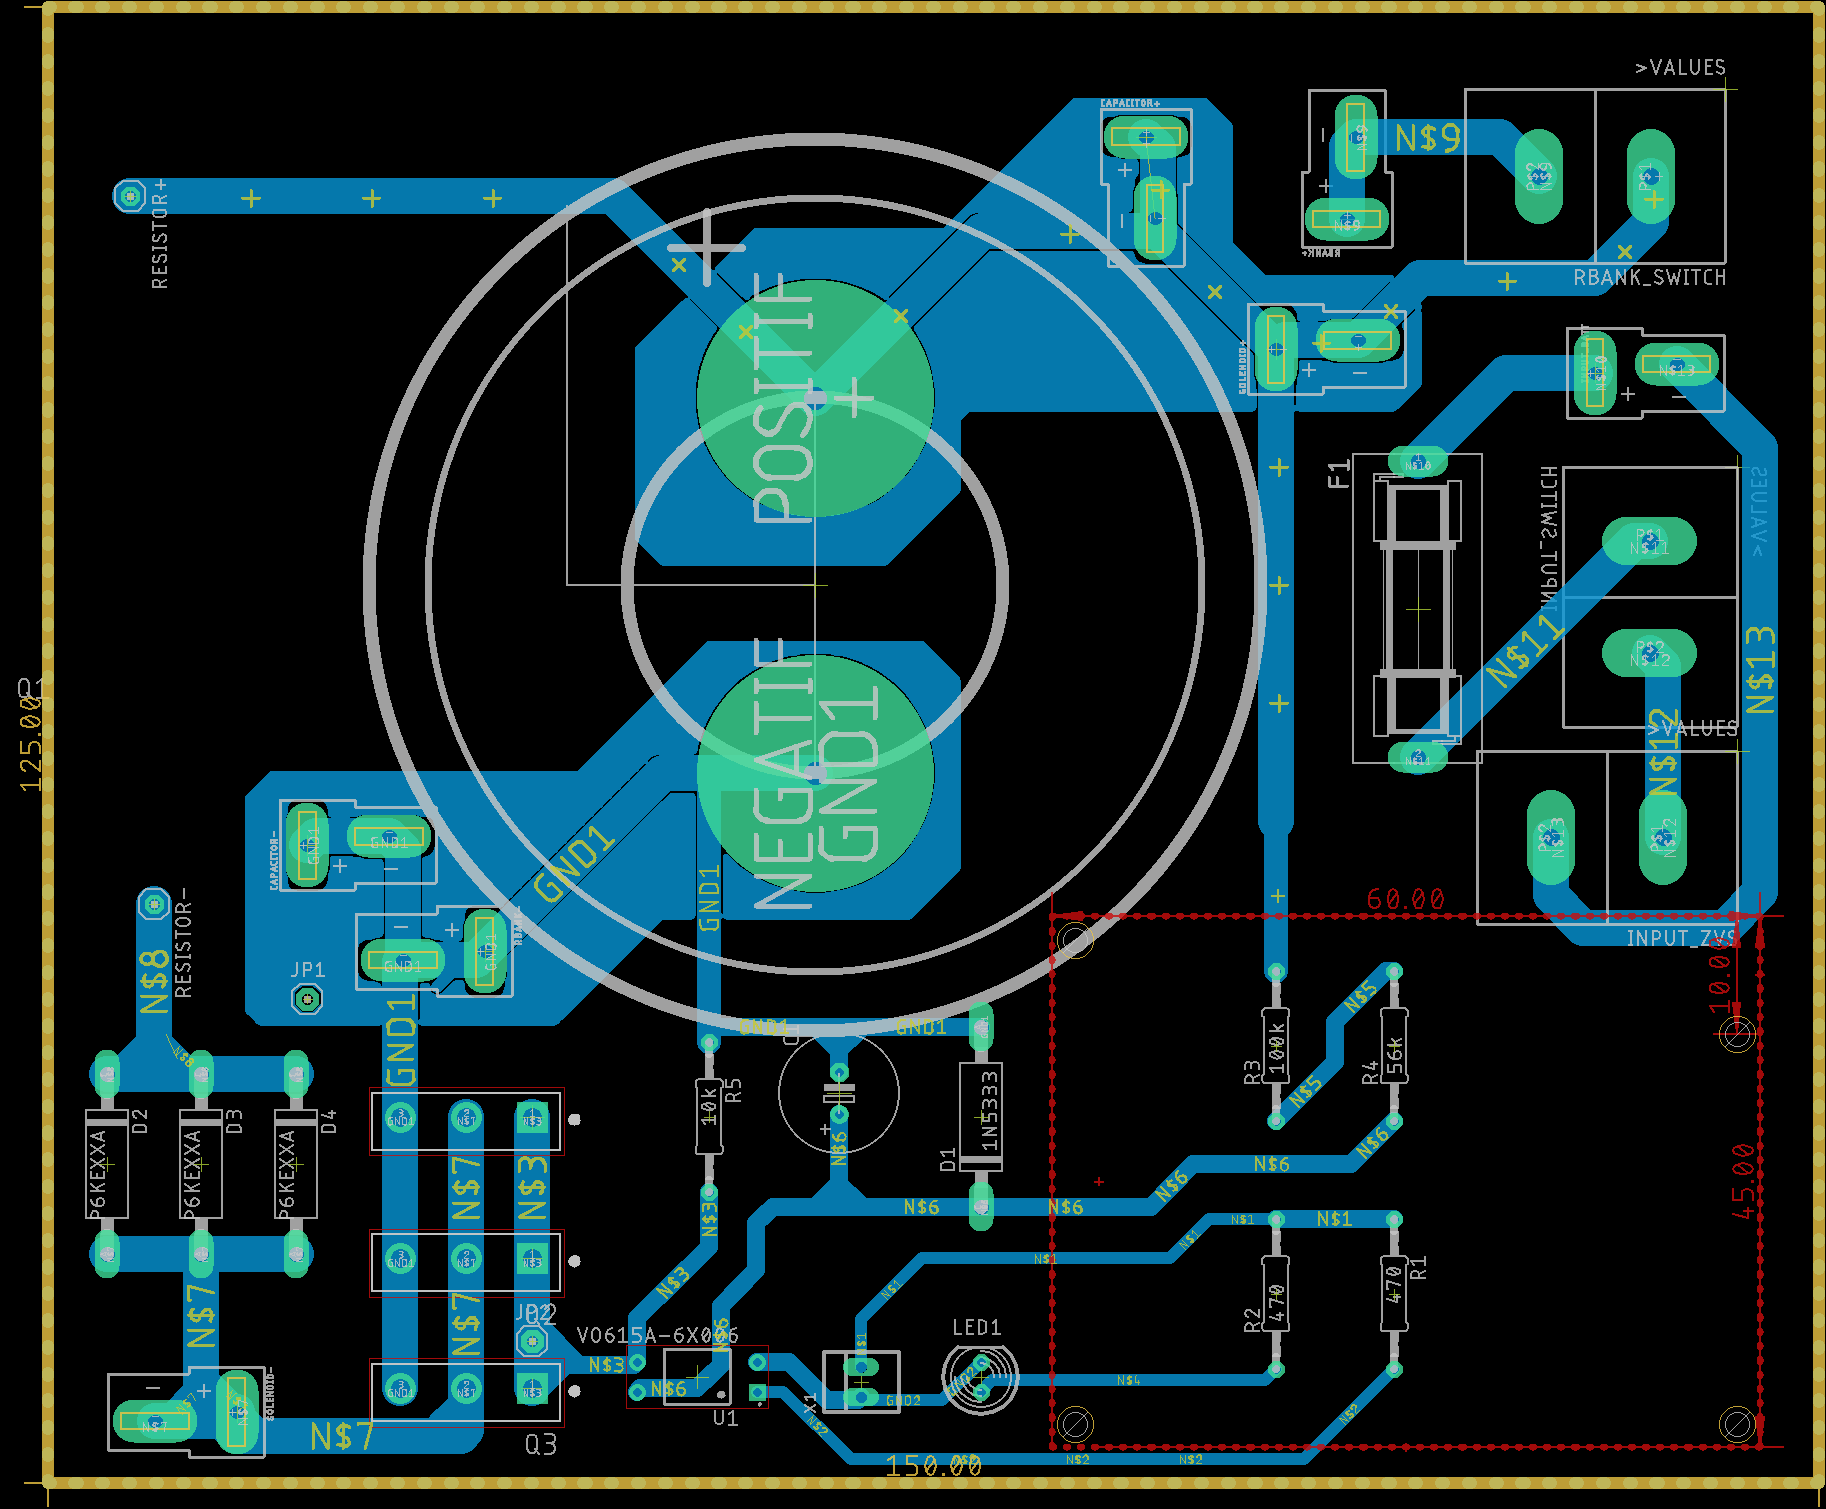
Figure 3. Solenoid kicker PCB.